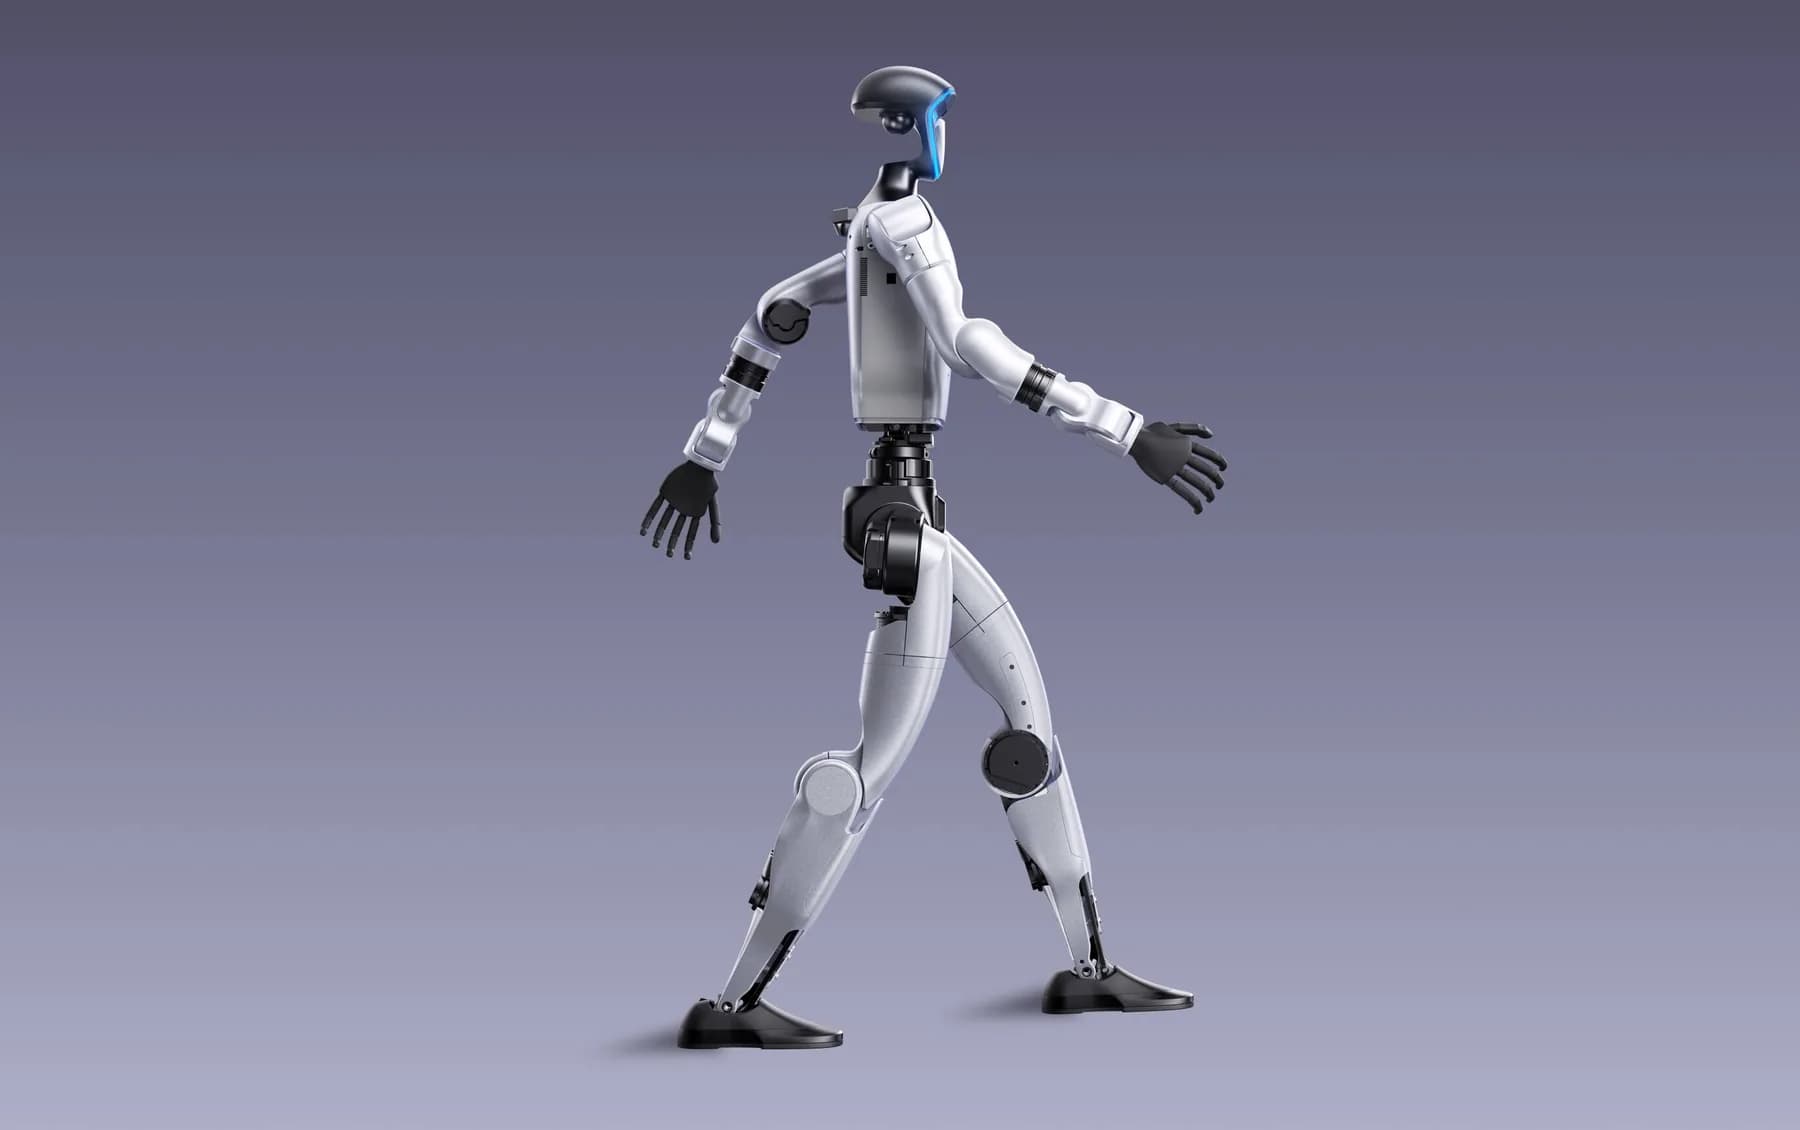
Mass production
Unitree
G1
Unitree's second humanoid robot and first small-scale model, launched on May 13, 2024 and billed by the compan…
Height132 cm
Degrees of freedom23
Arm payload2 kg
ResearchIndustrial
CN¥99,000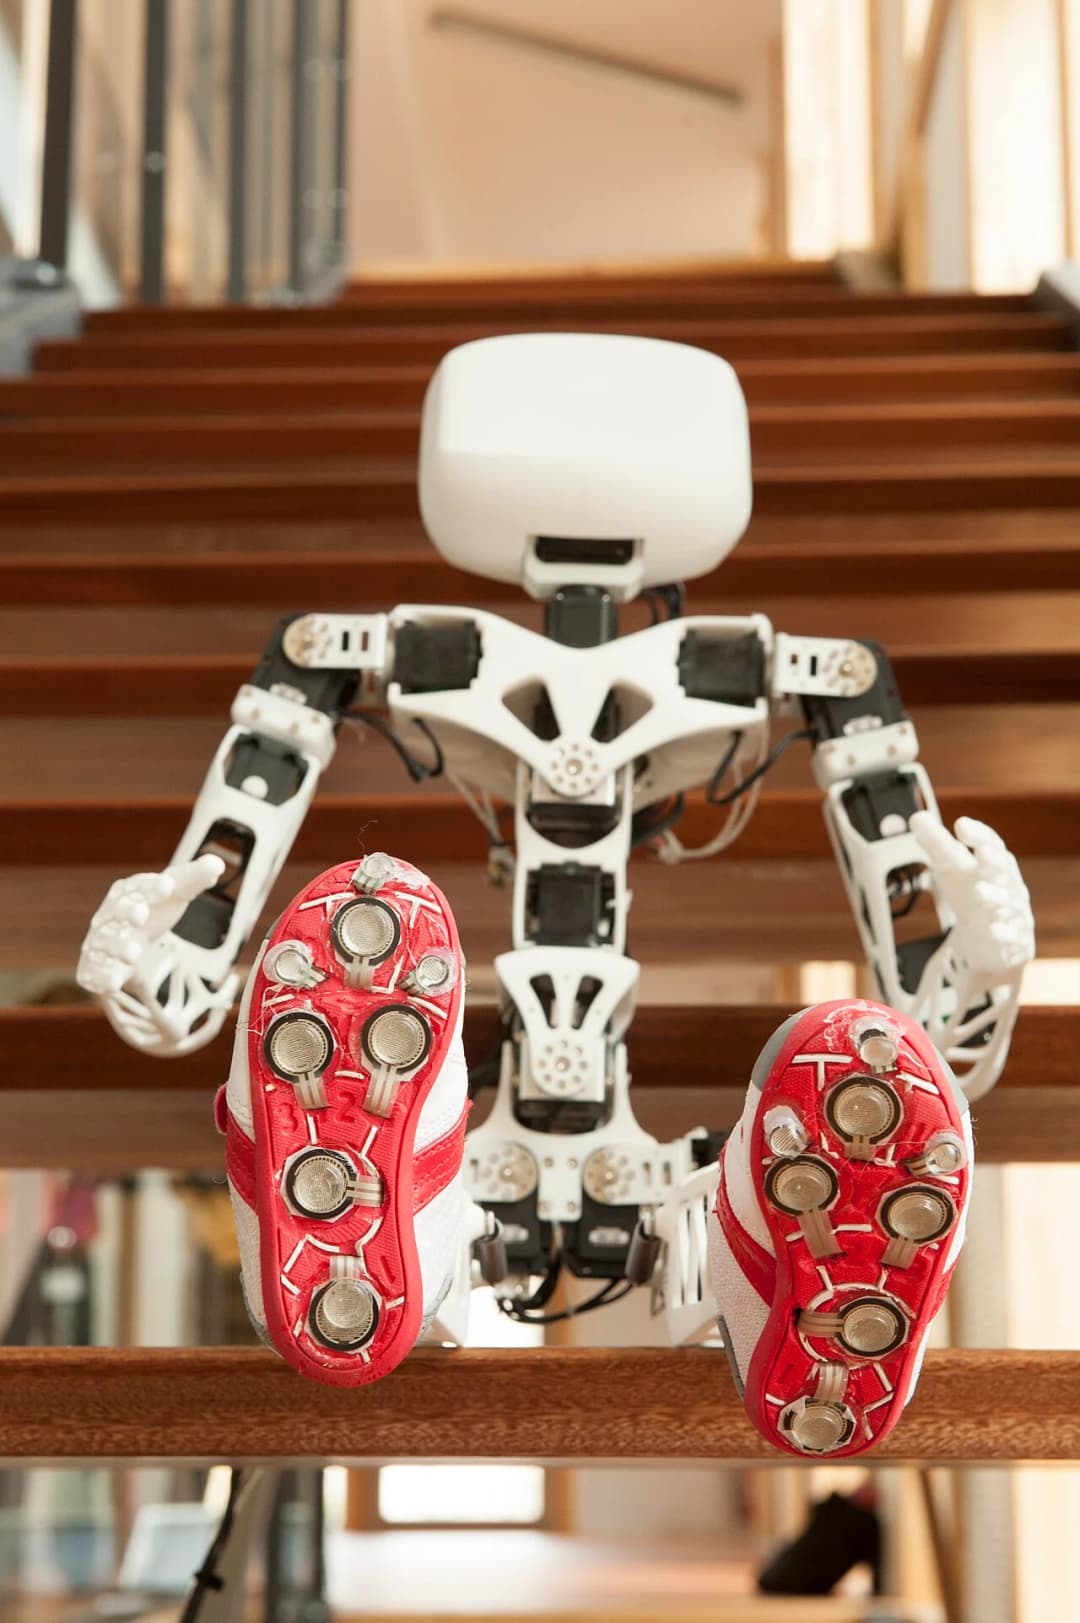
The open-source, 3D-printed humanoid that brought full-body robotics into classrooms and labs.
Poppy Humanoid is an open-source, 3D-printed humanoid created in 2012 by Inria's Flowers team with ENSTA ParisTech and the Cité des Sciences, designed as a low-cost platform for education and research. It stands 84 cm, weighs about 3 kg and has 25 degrees of freedom driven by RobotIS Dynamixel servos, programmed in Python through the pypot library. The design files, electronics and software were released openly and assembled kits were sold by resellers, while the smaller Poppy Torso variant targeted desktop use. The project is no longer actively developed, but Poppy remains a widely cited reference platform for open humanoid hardware.
| Height | 84 cm |
|---|---|
| Weight | 3 kg |
| Form factor | Compact |
| Locomotion | Bipedal |
|---|---|
| Degrees of freedom | 25 |
| DOF breakdown | 25 DOF: six per leg, five per arm, two for the head and one for the torso. |
| Actuators | RobotIS Dynamixel MX-series digital servos. |
| Compute | Raspberry Pi single-board computer plus a host PC running the pypot control stack. |
|---|---|
| Sensing | Joint position feedback from the servos and an IMU; cameras and depth sensors can be added through the open expansion ports. |
| Hands | 3D-printed simple hands/grippers. |
| Availability | Open-source plans remain downloadable; assembled kits are no longer actively sold and the project is community-maintained. |
|---|---|
| Target market | Education, academic research and open-source robotics communities. |
| SDK | pypot Python library; ROS bindings (poppy_ros). |
| Software / OS | pypot control library, Poppy documentation and simulation models for V-REP/Gazebo. |
| Deployments & partners | Schools, universities and maker labs, mainly in France and Europe. |
| Variants | Poppy Humanoid · Poppy Torso |
Claims on this profile are linked to primary reporting and manufacturer material where available.
Specifications are sourced from public materials and may change. Always confirm commercial terms with the manufacturer.
Unitree's second humanoid robot and first small-scale model, launched on May 13, 2024 and billed by the compan…
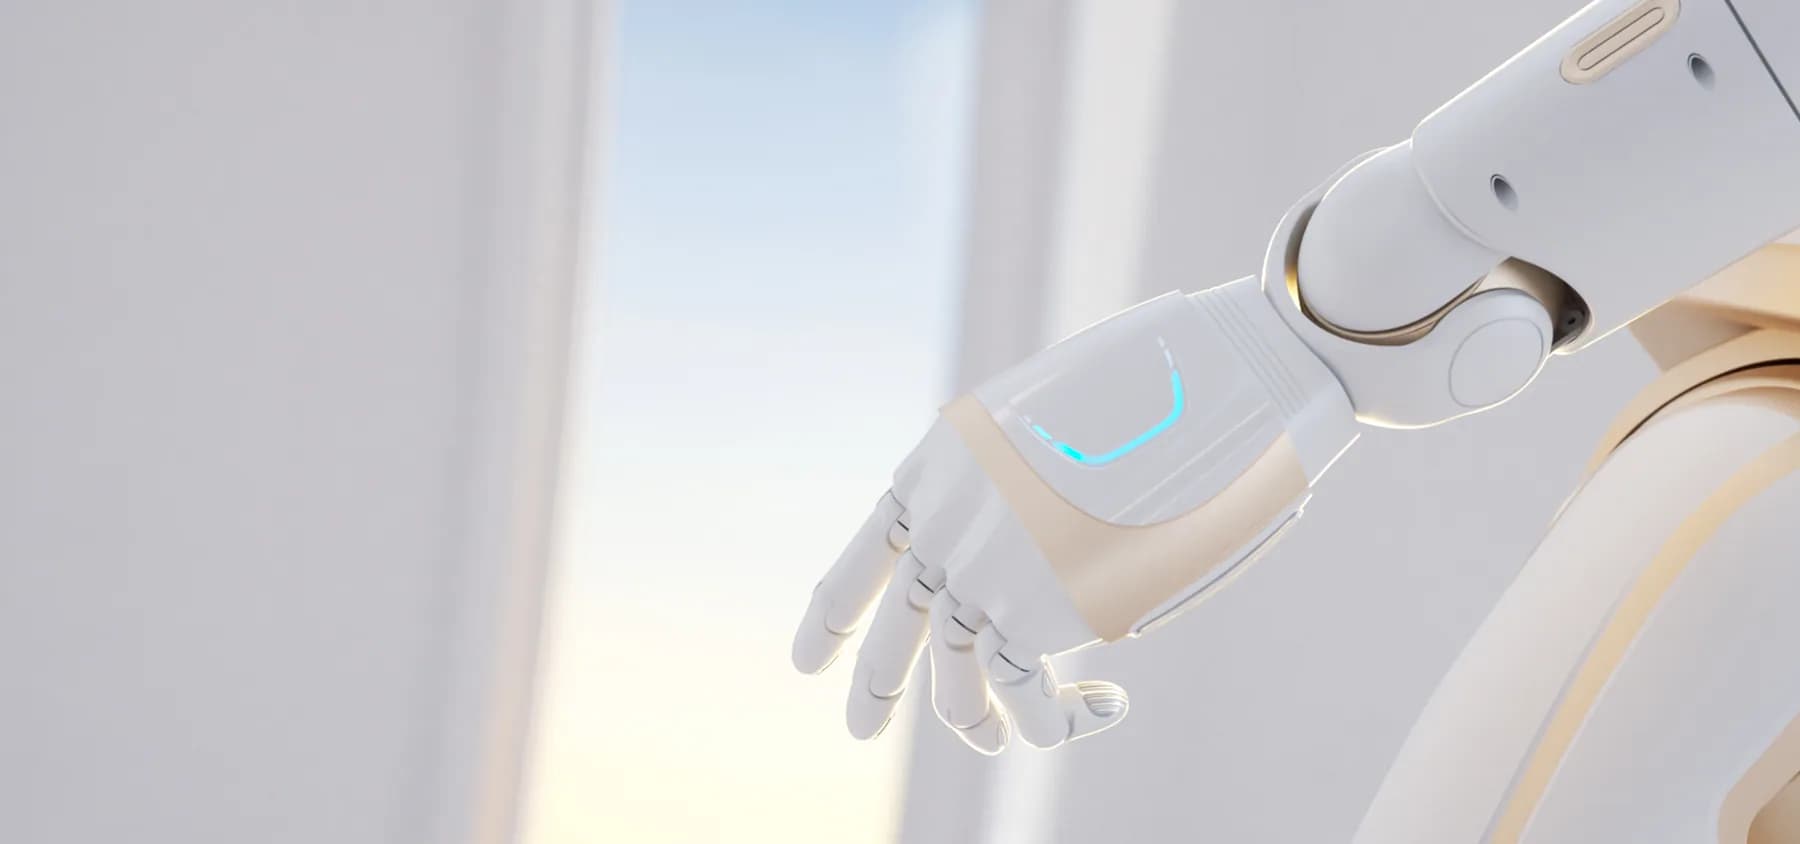
UBTech's next-generation large humanoid service robot, globally unveiled at WAIC 2021 in Shanghai on July 7, 2…
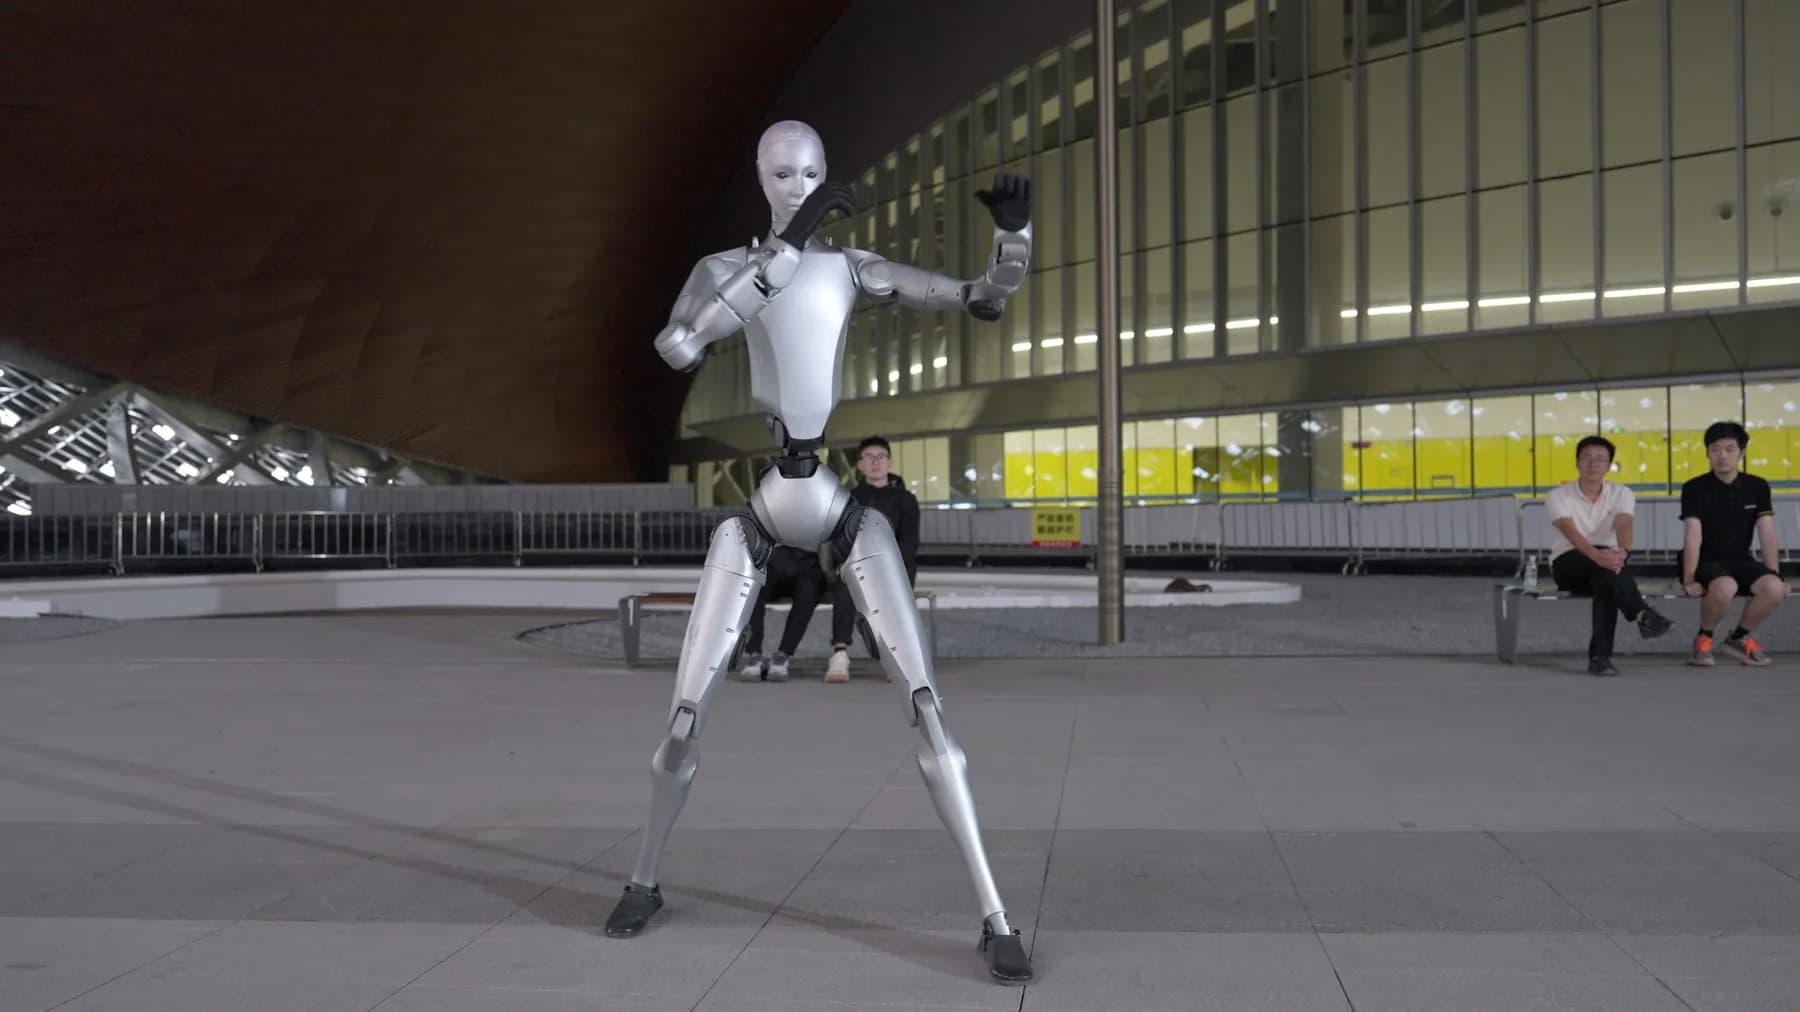
Unitree's fourth humanoid robot and second full-size model after the H1, launched on October 20, 2025 and desc…
Figure 03 was officially launched on October 9, 2025, the same day as its TIME Best Inventions cover, and is F…