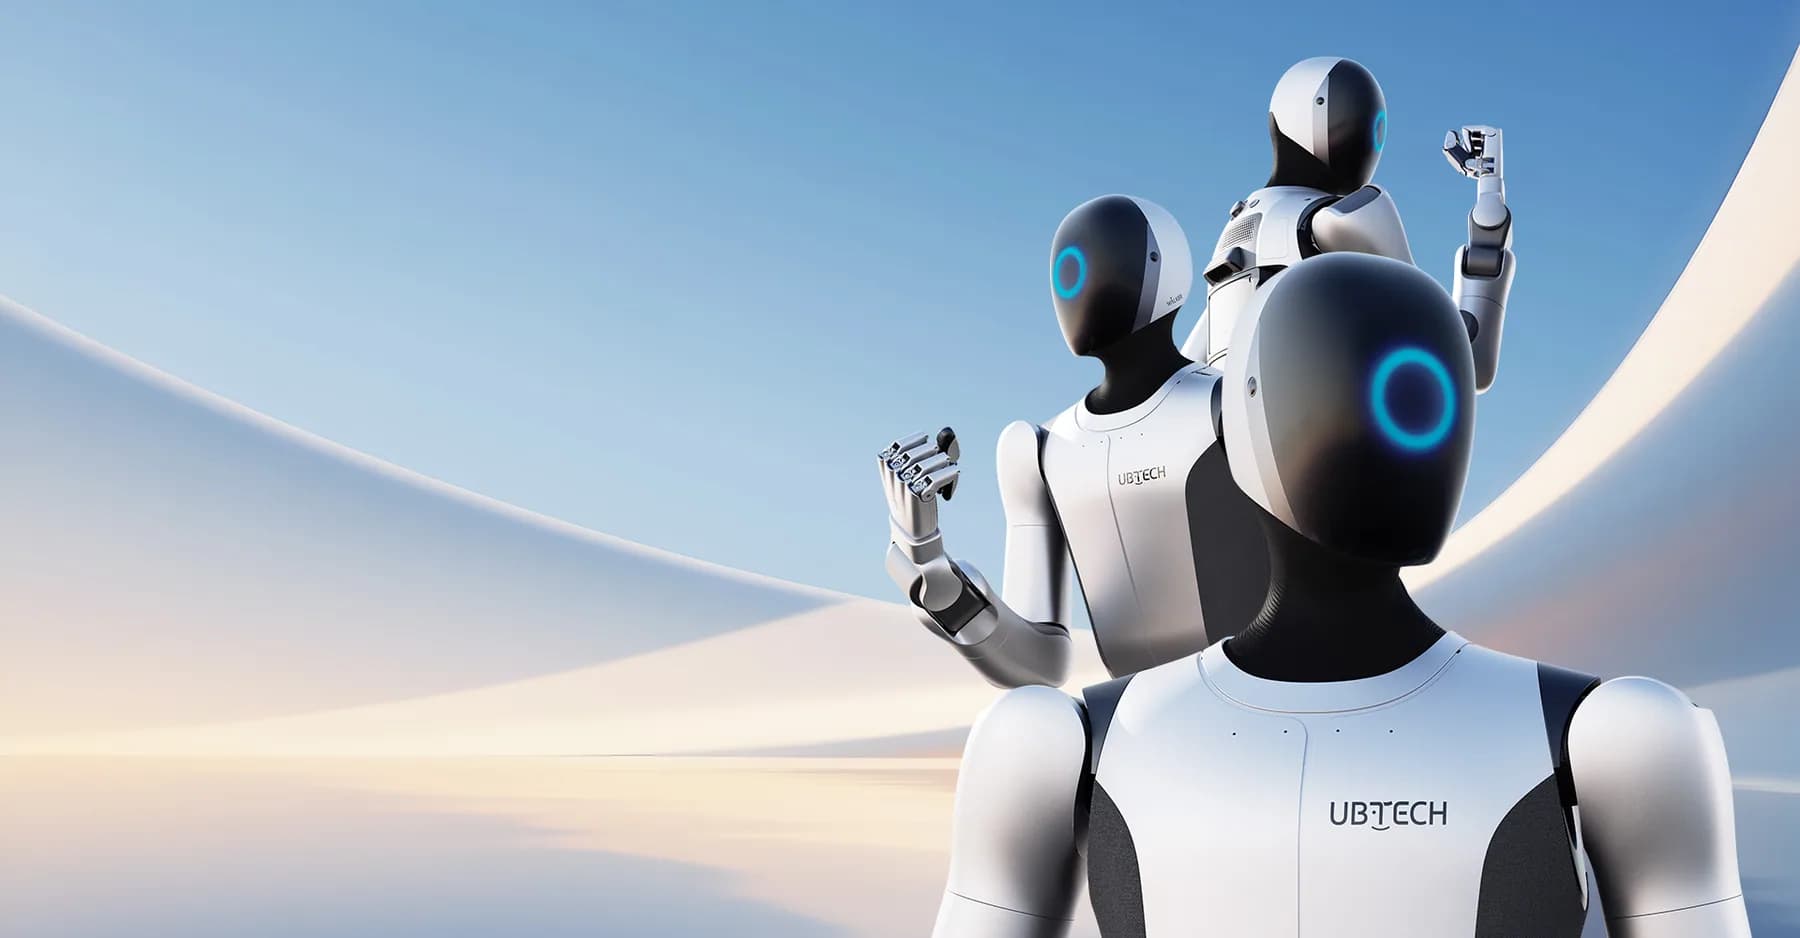
Mass production
UBTECH
Walker S2
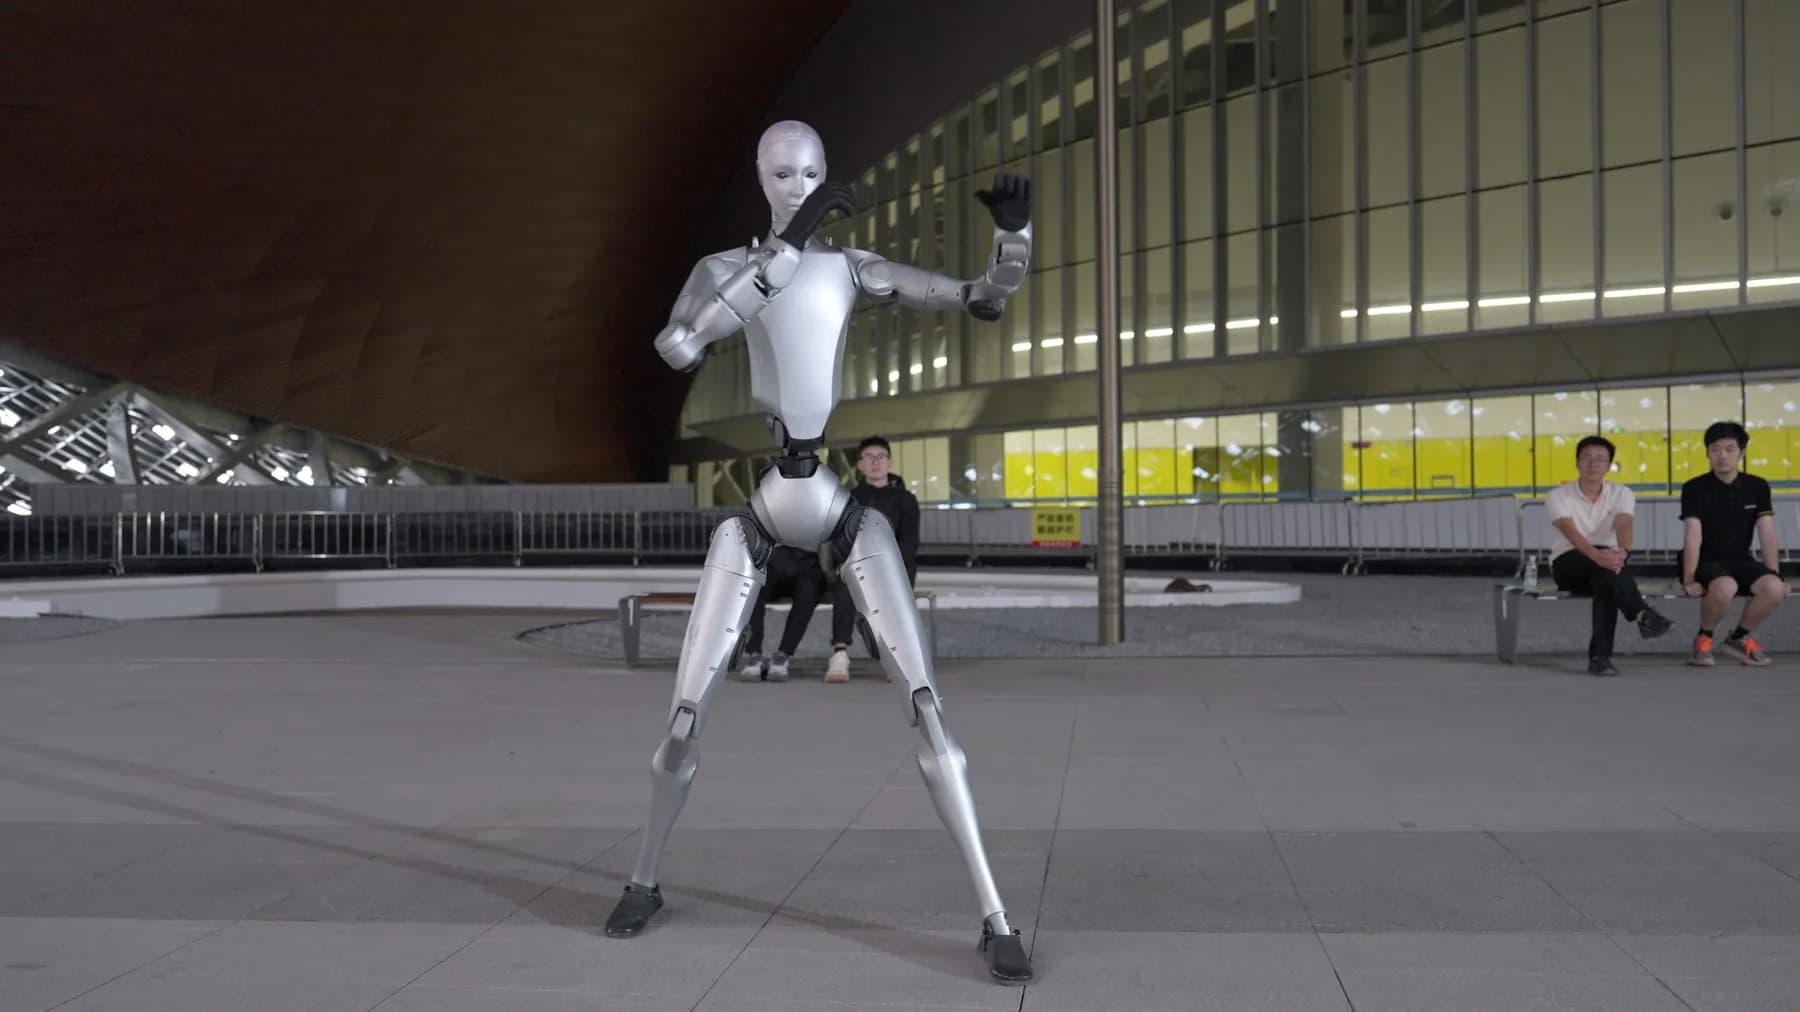
UBTech's all-new full-size industrial humanoid, launched on July 23, 2025, standing 176 cm and weighing 70 kg…
Height176 cm
Degrees of freedom52
Arm payload—
Industrial
Price on request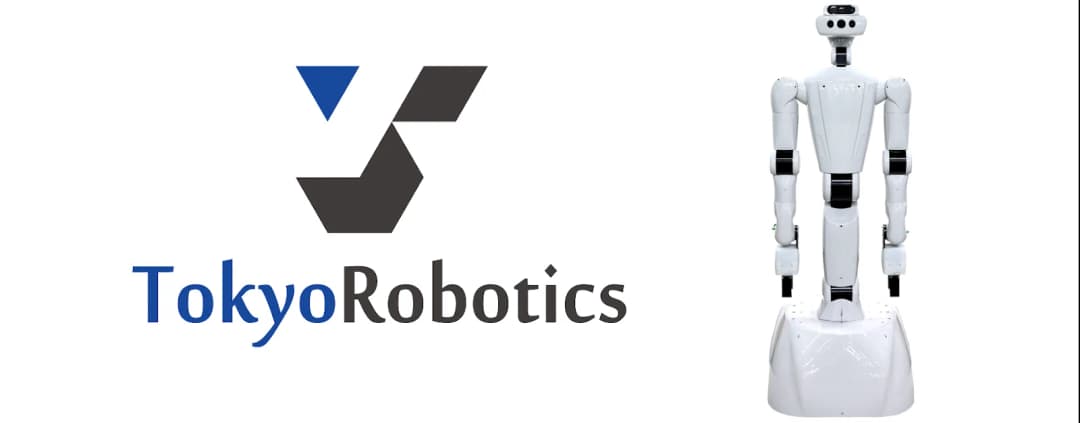
A torque-controlled humanoid upper body on an omnidirectional base, built for contact-rich AI research.
Torobo is Tokyo Robotics' research humanoid: a head, torso and two 7-DOF torque-sensing arms mounted on a four-axis omnidirectional wheeled base rather than legs. The current specification lists 166 cm and about 160 kg, 8 kg payload per arm in the worst posture (20 kg instantaneous), three hours of battery and a full ROS/ROS2 software stack. It is sold mainly to universities and corporate R&D groups for force-controlled assembly, cooking and physical interaction research, and Tokyo Robotics now also lists Torobo among its legacy products while keeping the platform page online.
| Height | 166 cm |
|---|---|
| Weight | 160 kg |
| Form factor | Torso / desktop |
| Locomotion | Wheeled |
|---|---|
| Degrees of freedom | 24 |
| DOF breakdown | 24 DOF: two 7-DOF arms, 3-DOF waist, 3-DOF neck and 4-DOF omnidirectional base, excluding optional hands. |
| Arm payload | 8 kg |
| Battery life | 3 h |
| Actuators | Electric joint actuators with link-side torque sensors and safety brakes that hold posture on power loss. |
| Compute | Two onboard PCs (robot control and image acquisition); the 2024 brochure offers an optional Intel Core i5 13th-gen head PC with NVIDIA RTX 4070. |
|---|---|
| Sensing | Head with wide-angle stereo camera, fisheye camera, depth camera and stereo microphone; 15-bit link-side torque sensors in all arm and waist joints; 20-bit absolute encoders. |
| Hands | Optional 3-finger simple hand or 4-finger dexterous hand. |
| Availability | Sold to universities and corporate research groups; Tokyo Robotics lists Torobo among legacy products (2022) while maintaining its specification page. |
|---|---|
| Target market | AI and robotics research groups, and industrial contact-task prototyping. |
| SDK | ROS and ROS2 packages; MoveIt and Gazebo integration. |
| Software / OS | Cartesian impedance control, ZMP-based fall prevention, self-collision monitoring and ROS2 tooling. |
| Deployments & partners | University and corporate research labs, including Waseda University and Tokyo Women's Medical University demos. |
| Safety & certifications | Torque-sensing contact stops, safety brakes, ZMP fall monitoring and real-time self-collision monitoring. |
| Variants | Torobo with head unit · 3-finger simple hand · 4-finger dexterous hand · Torobo Hand |
Claims on this profile are linked to primary reporting and manufacturer material where available.
Specifications are sourced from public materials and may change. Always confirm commercial terms with the manufacturer.
UBTech's all-new full-size industrial humanoid, launched on July 23, 2025, standing 176 cm and weighing 70 kg…
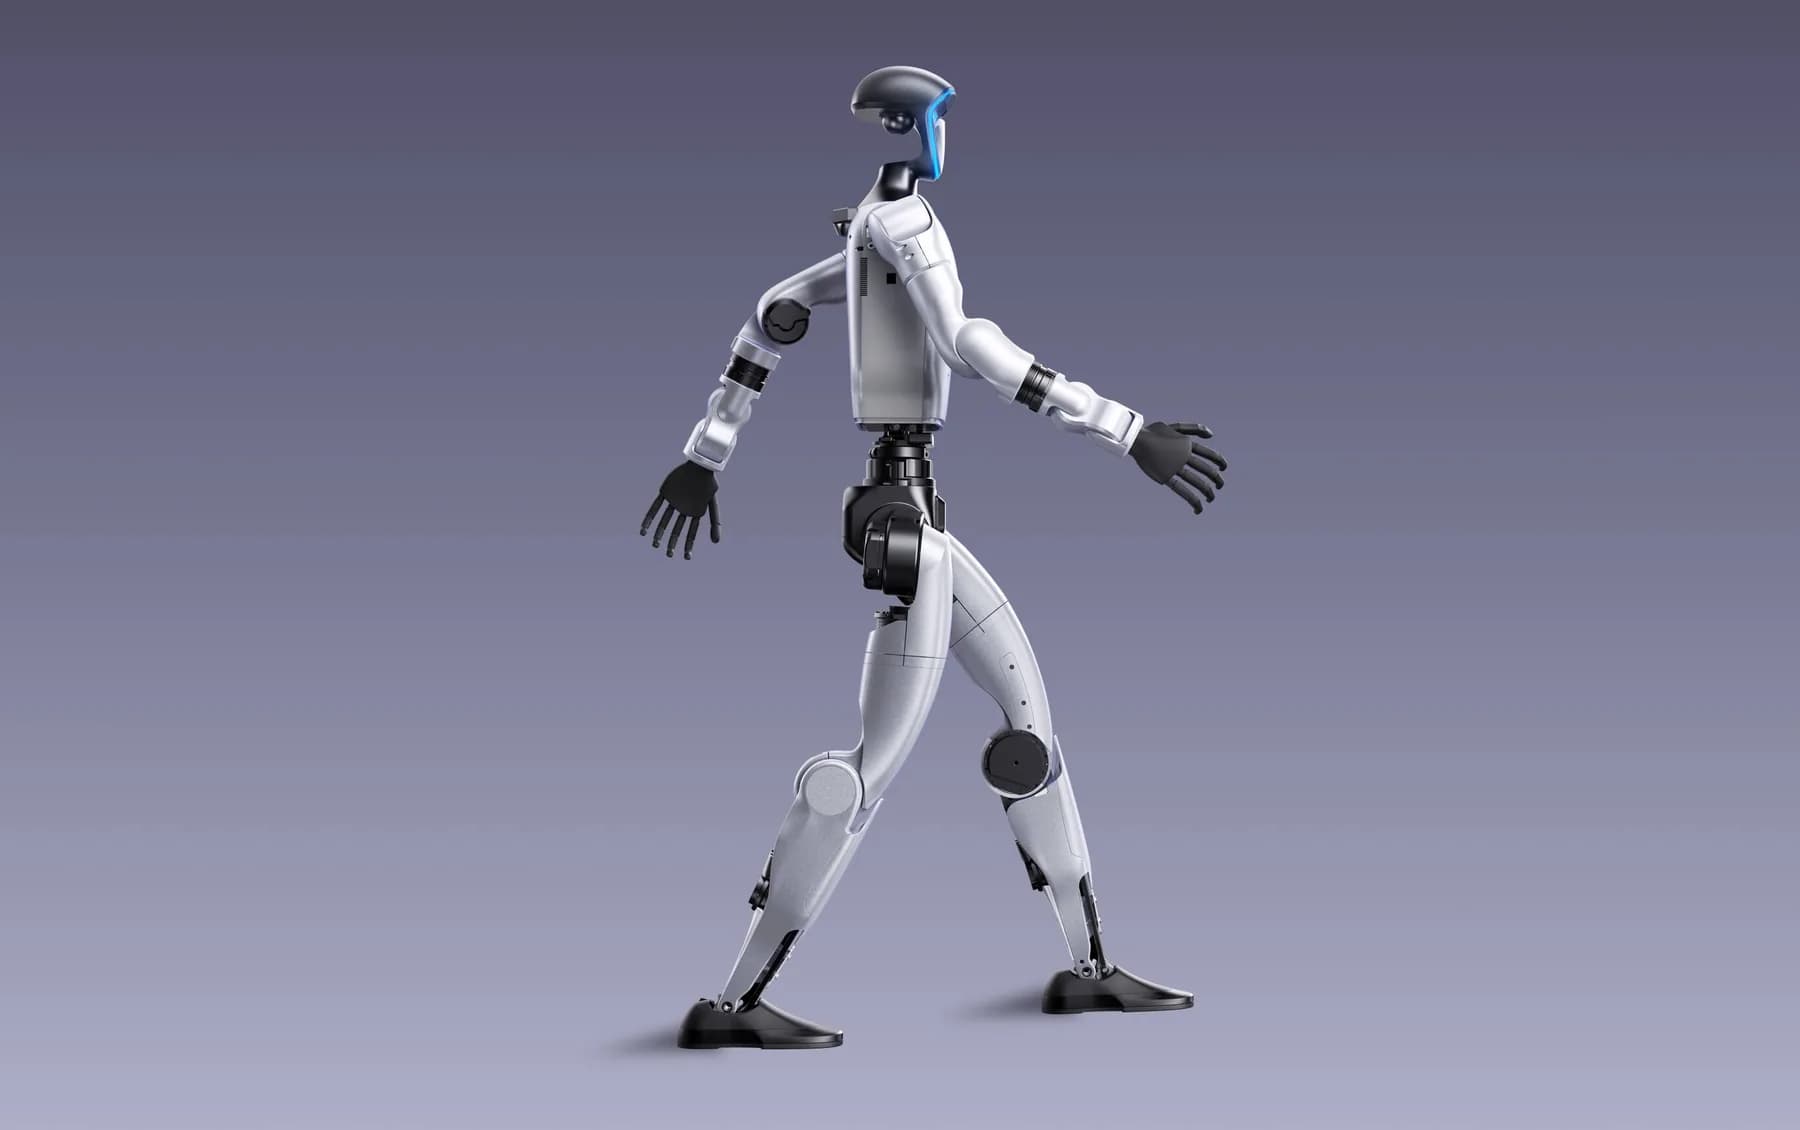
Unitree's second humanoid robot and first small-scale model, launched on May 13, 2024 and billed by the compan…
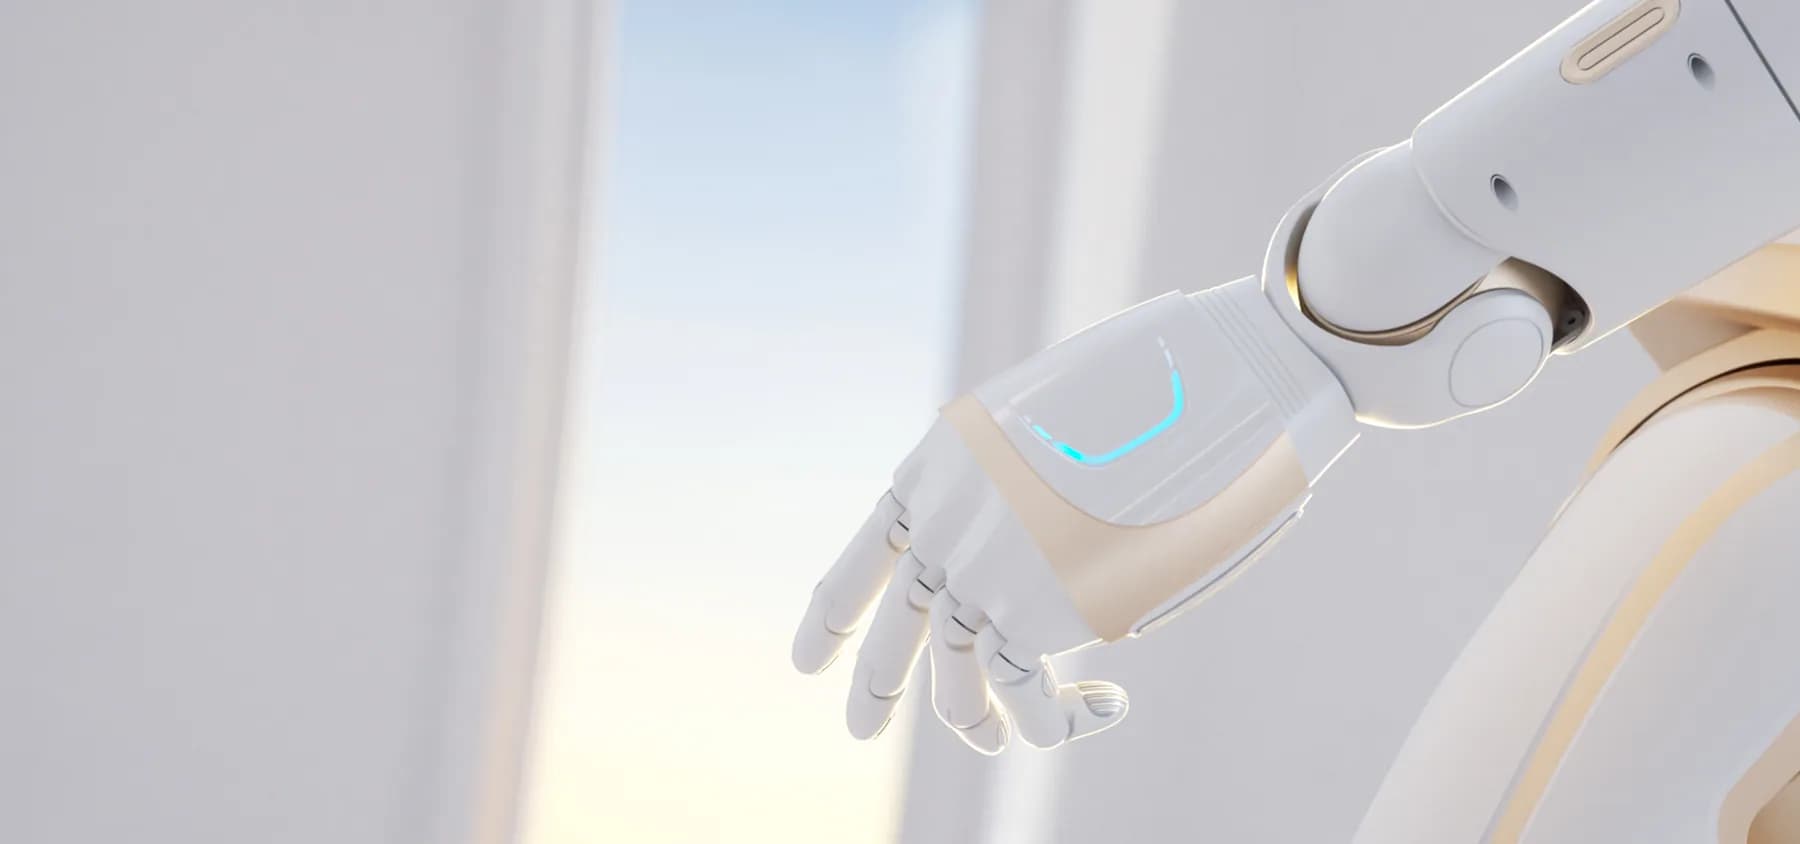
UBTech's next-generation large humanoid service robot, globally unveiled at WAIC 2021 in Shanghai on July 7, 2…
Unitree's fourth humanoid robot and second full-size model after the H1, launched on October 20, 2025 and desc…