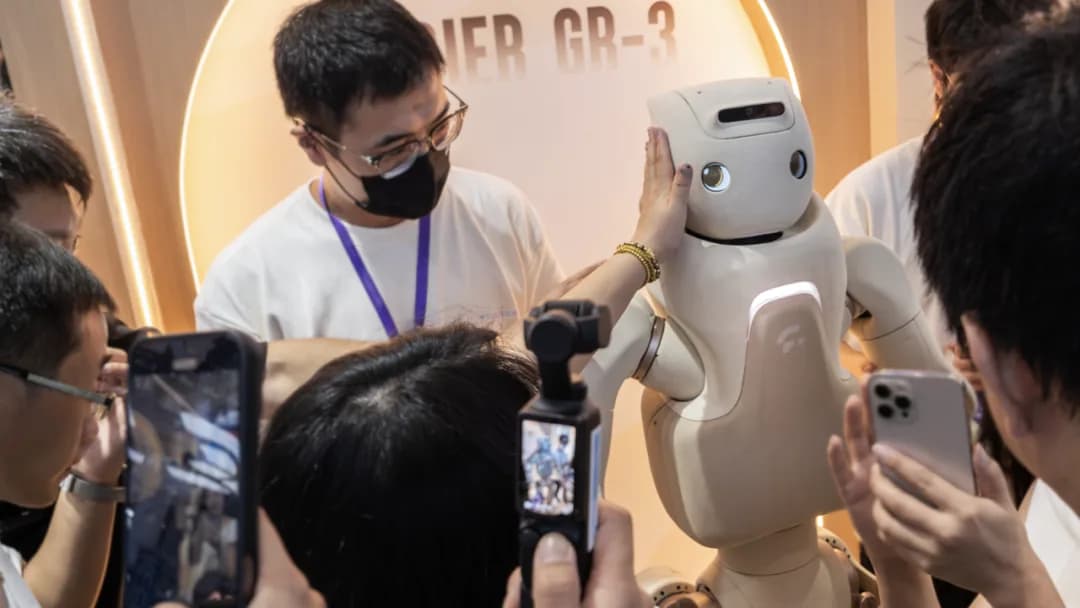
Pilot deployment
Fourier Intelligence
GR-3
GR-3 is the third-generation full-size humanoid robot in Fourier's GRx series, launched on August 6, 2025, and…
Height165 cm
Degrees of freedom55
Arm payload3 kg
HomeHealthcare
Price on request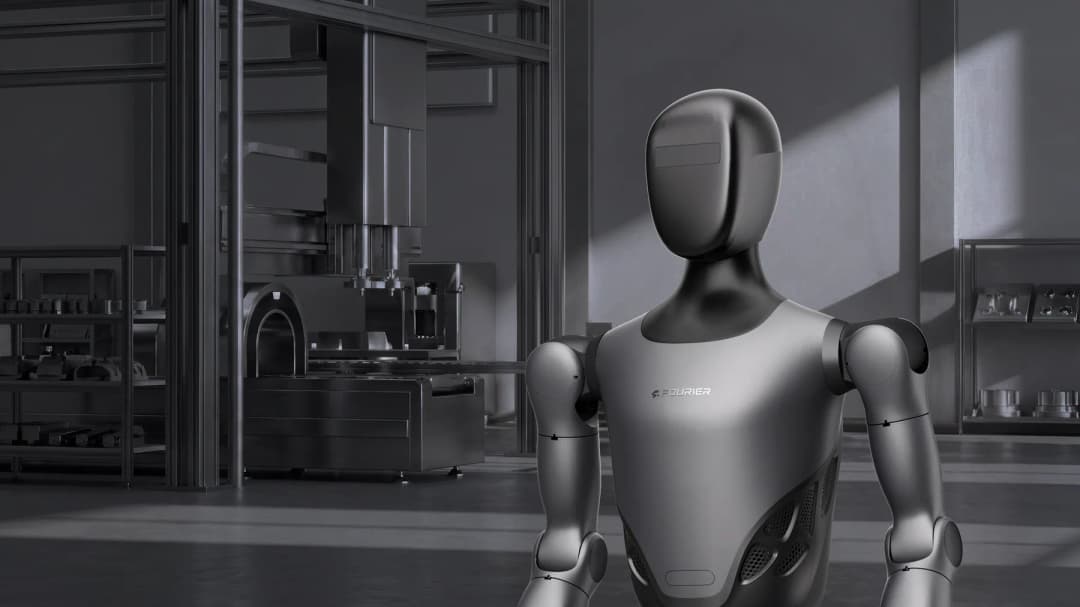
GR-2 is Fourier Intelligence's second-generation general-purpose humanoid, launched on September 26, 2024 in Shanghai: 175 cm, 63 kg, 53 degrees of freedom and a 3 kg single-arm payload.
GR-2 is Fourier Intelligence's second-generation general-purpose humanoid robot, launched on September 26, 2024 at Zhangjiang Robot Valley in Shanghai. It stands 175 cm tall, weighs 63 kg, has 53 degrees of freedom in total (including 12 per hand), carries a 3 kg payload per arm and runs for about 2 hours. Compared with GR-1, GR-2 is comprehensively upgraded in degrees of freedom, dexterous hands, joint torque, battery life and development-framework support, with the company's stated vision of "building the best embodied platform for artificial intelligence".
| Height | 175 cm |
|---|---|
| Weight | 63 kg |
| Form factor | Full-size |
| Locomotion | Bipedal |
|---|---|
| Degrees of freedom | 53 |
| Arm payload | 3 kg |
| Top speed | 5 km/h |
| Battery life | 2 h |
| Actuators | Seven custom FSA 2.0 integrated actuator models (used in the hips, ankles and other joints), maximum joint peak torque above 380 N·m, dual-encoder system (2× encoder accuracy), joint layout changed from parallel to serial |
| Speed notes | Official walking speed about 1.4 m/s |
| Battery notes | Battery capacity doubled versus the previous generation, runtime extended to 2 hours, supporting direct charging and a removable swap-battery option |
| Compute | Supports NVIDIA Isaac Lab, ROS, MuJoCo, Webots and other open-source frameworks, with development interface options based on mainstream programming languages |
|---|---|
| Sensing | Depth camera · Six array tactile sensors (dexterous hands) |
| Hands | 12-DOF tactile biomimetic dexterous hands (replicating the shape and size of human hands), with six array tactile sensors and motion-control algorithms that sense grip force in real time |
| Availability | Public demonstrations; not generally available |
|---|
Claims on this profile are linked to primary reporting and manufacturer material where available.
Specifications are sourced from public materials and may change. Always confirm commercial terms with the manufacturer.
GR-3 is the third-generation full-size humanoid robot in Fourier's GRx series, launched on August 6, 2025, and…
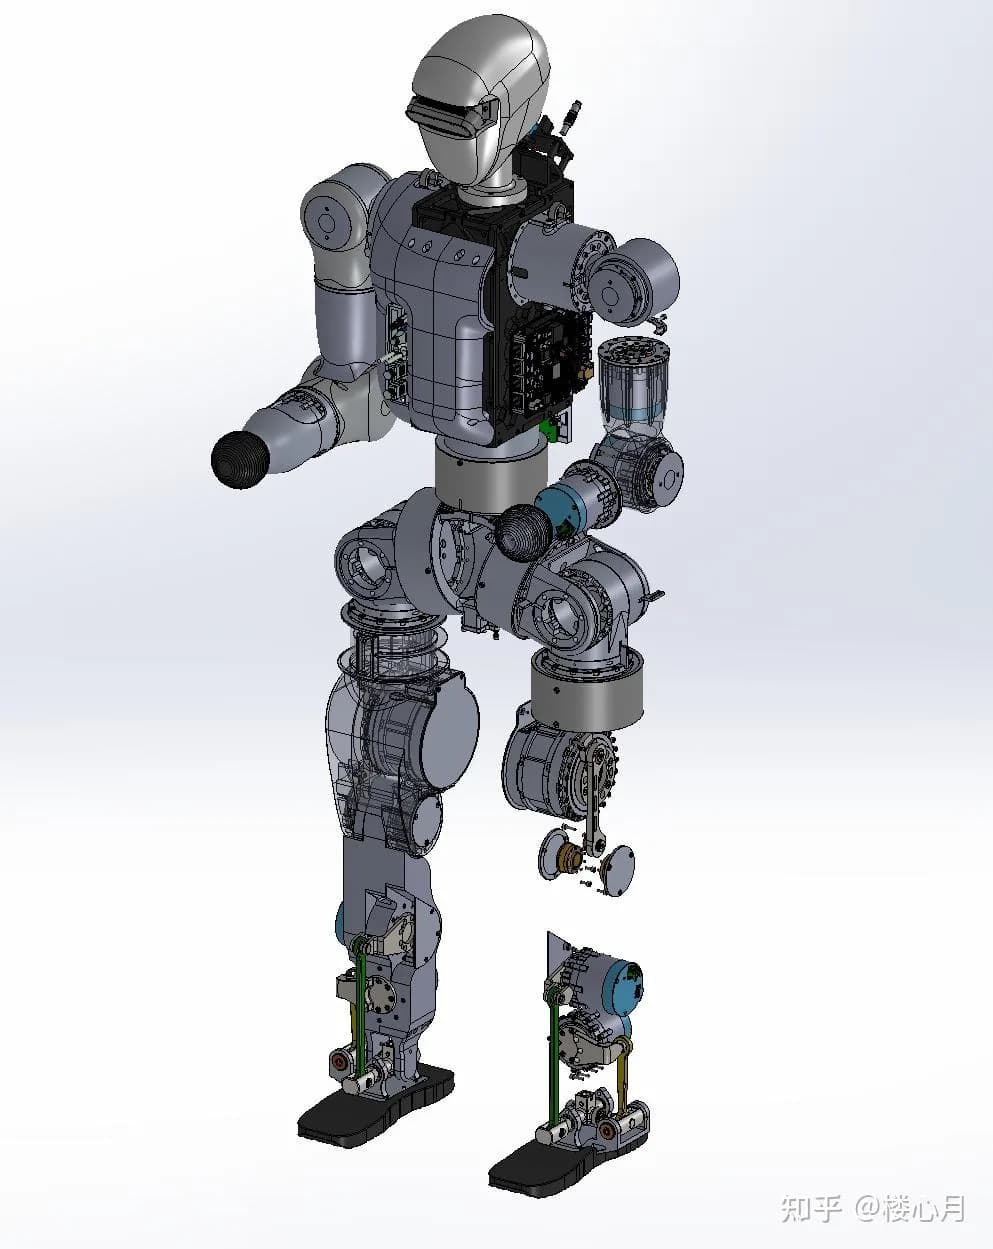
The Fourier N1 is Fourier Intelligence's first open-source humanoid robot, released on April 11, 2025, and the…
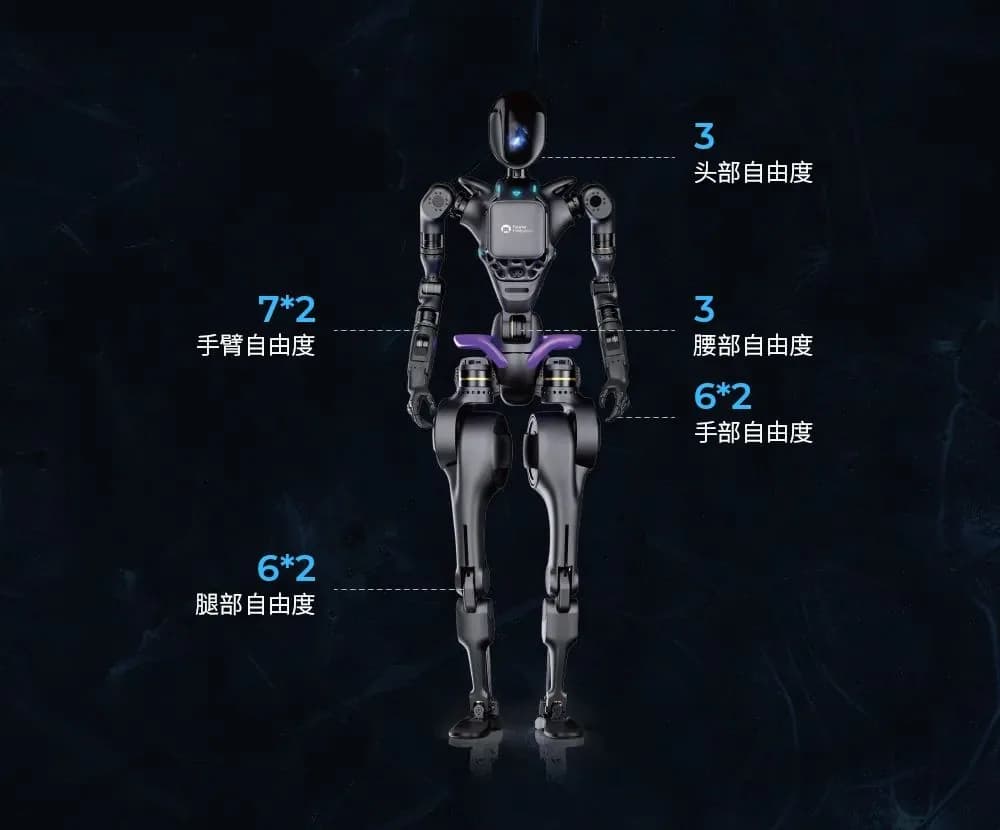
GR-1 is Fourier Intelligence's first general-purpose humanoid, unveiled on July 6, 2023 at the opening of WAIC…
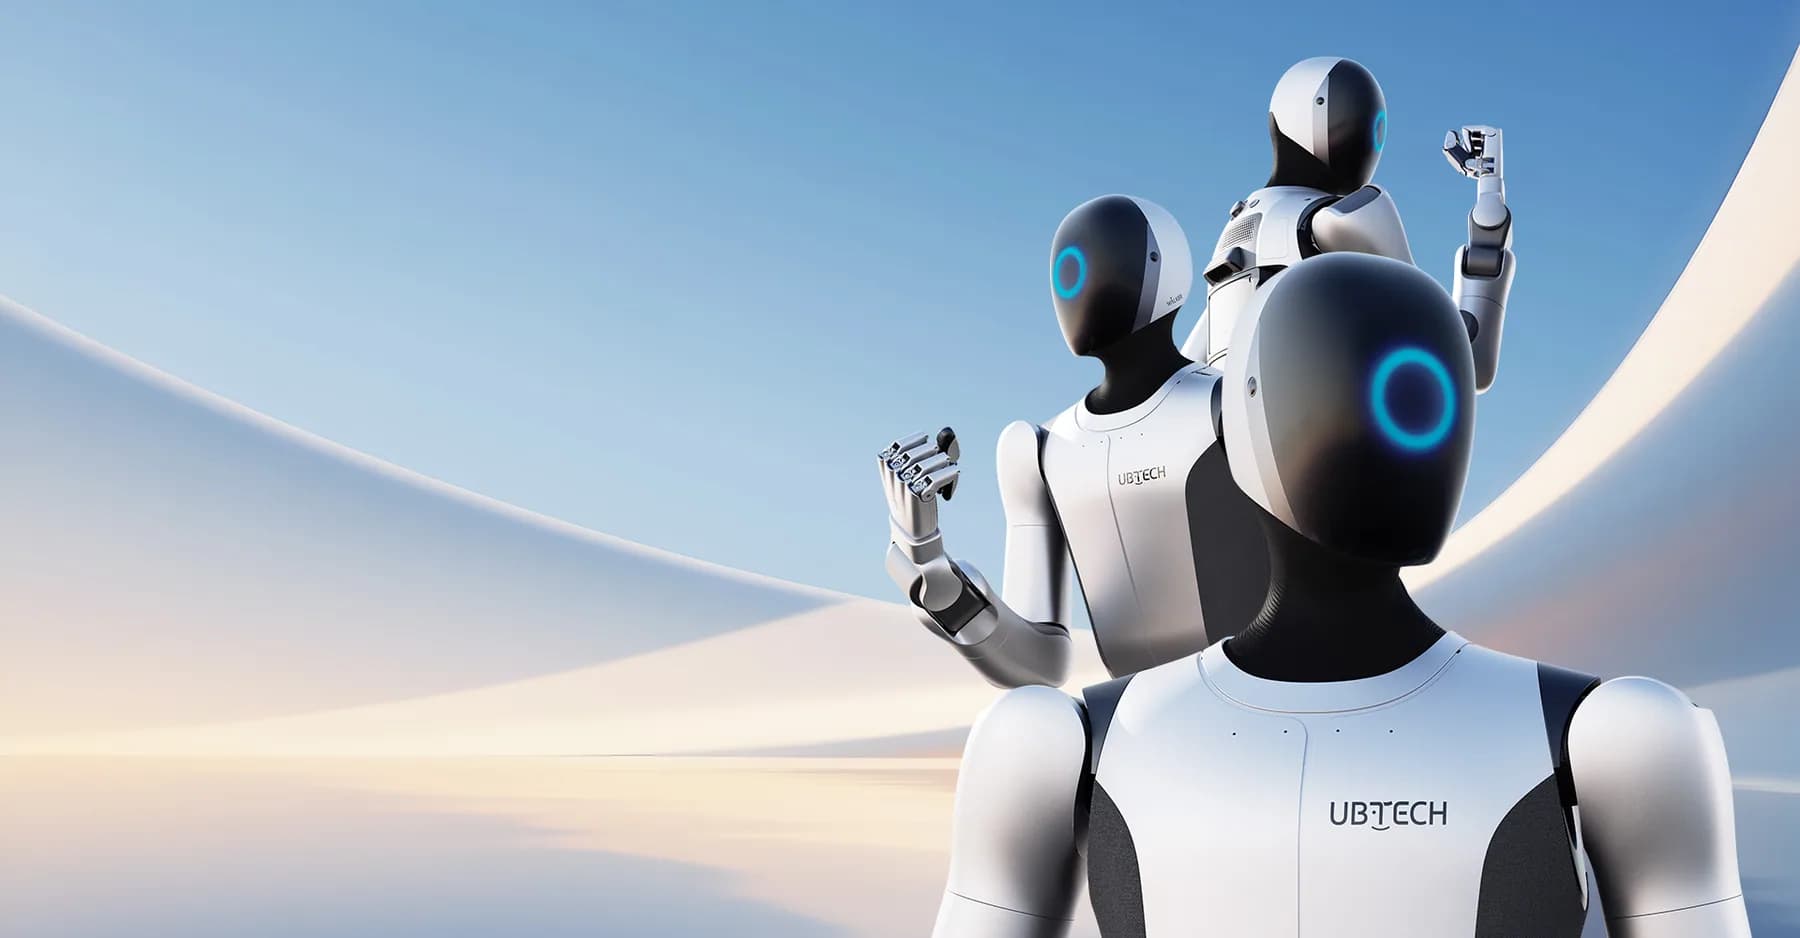
UBTech's all-new full-size industrial humanoid, launched on July 23, 2025, standing 176 cm and weighing 70 kg…