German Aerospace Center (DLR)
Agile Justin
DLR's 53-DOF torque-controlled humanoid for learning-based dexterous manipulation.
Height191 cm
Degrees of freedom53
Arm payload15 kg
ResearchIndustrial
Price on request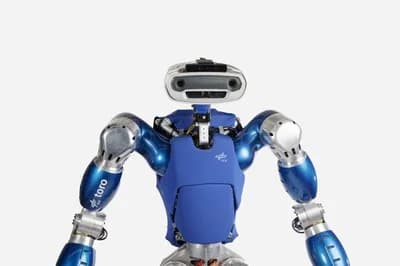
DLR's torque-controlled biped, built to study robust walking and multi-contact balance.
TORO (Torque-Controlled Humanoid Robot) is a German research biped from DLR's Institute of Robotics and Mechatronics, introduced in 2013. It stands 174 cm, weighs 76 kg and has 39 degrees of freedom, with joint torque sensing throughout and lightweight-robot arm technology. TORO is used to study robust walking, stair climbing and multi-contact scenarios.
| Height | 174 cm |
|---|---|
| Weight | 76 kg |
| Form factor | Full-size |
| Locomotion | Bipedal |
|---|---|
| Degrees of freedom | 39 |
| Arm payload | 10 kg |
| Battery life | 1 h |
| Actuators | 25 LWR-derived motor units plus two Dynamixel neck servos. |
| Compute | Two Intel Core i7 torso PCs and one Intel Core i3 head PC running real-time Linux. |
|---|---|
| Sensing | Joint position and torque sensors, 6-axis force/torque sensors in each ankle, torso and head IMUs, ASUS Xtion Pro, two Firefly cameras and a RealSense SR300. |
| Hands | Six-DOF hands. |
| Availability | Prototype |
|---|
Claims on this profile are linked to primary reporting and manufacturer material where available.
Specifications are sourced from public materials and may change. Always confirm commercial terms with the manufacturer.
DLR's 53-DOF torque-controlled humanoid for learning-based dexterous manipulation.
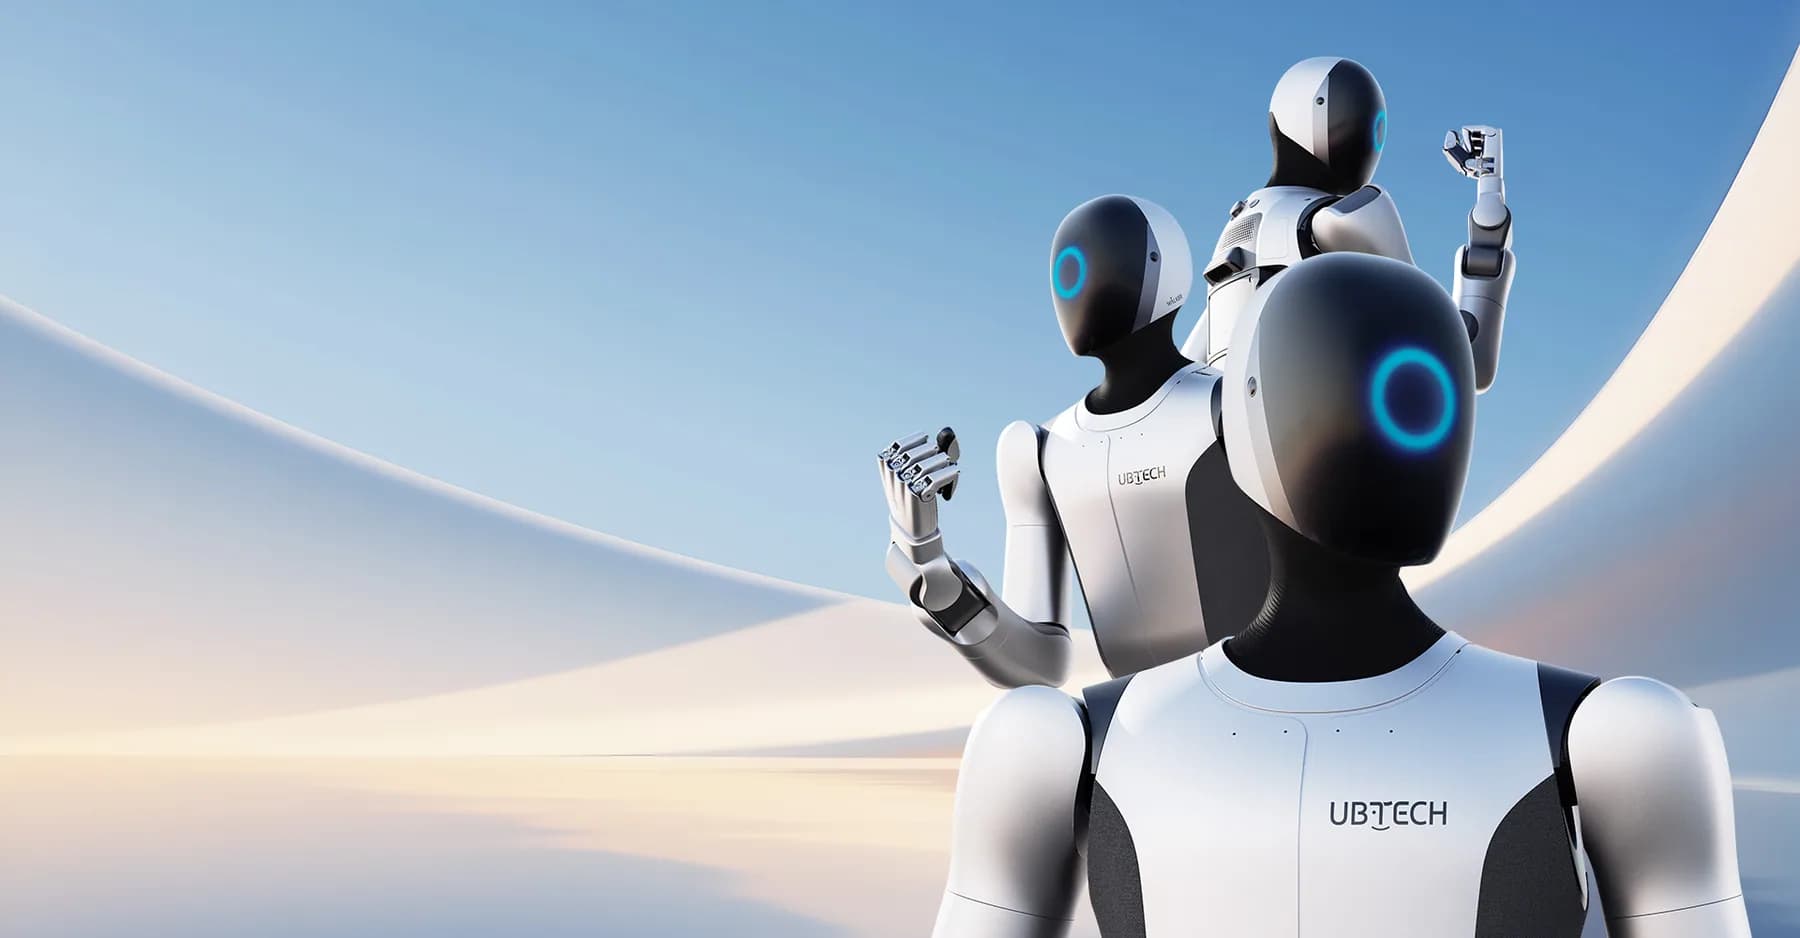
UBTech's all-new full-size industrial humanoid, launched on July 23, 2025, standing 176 cm and weighing 70 kg…
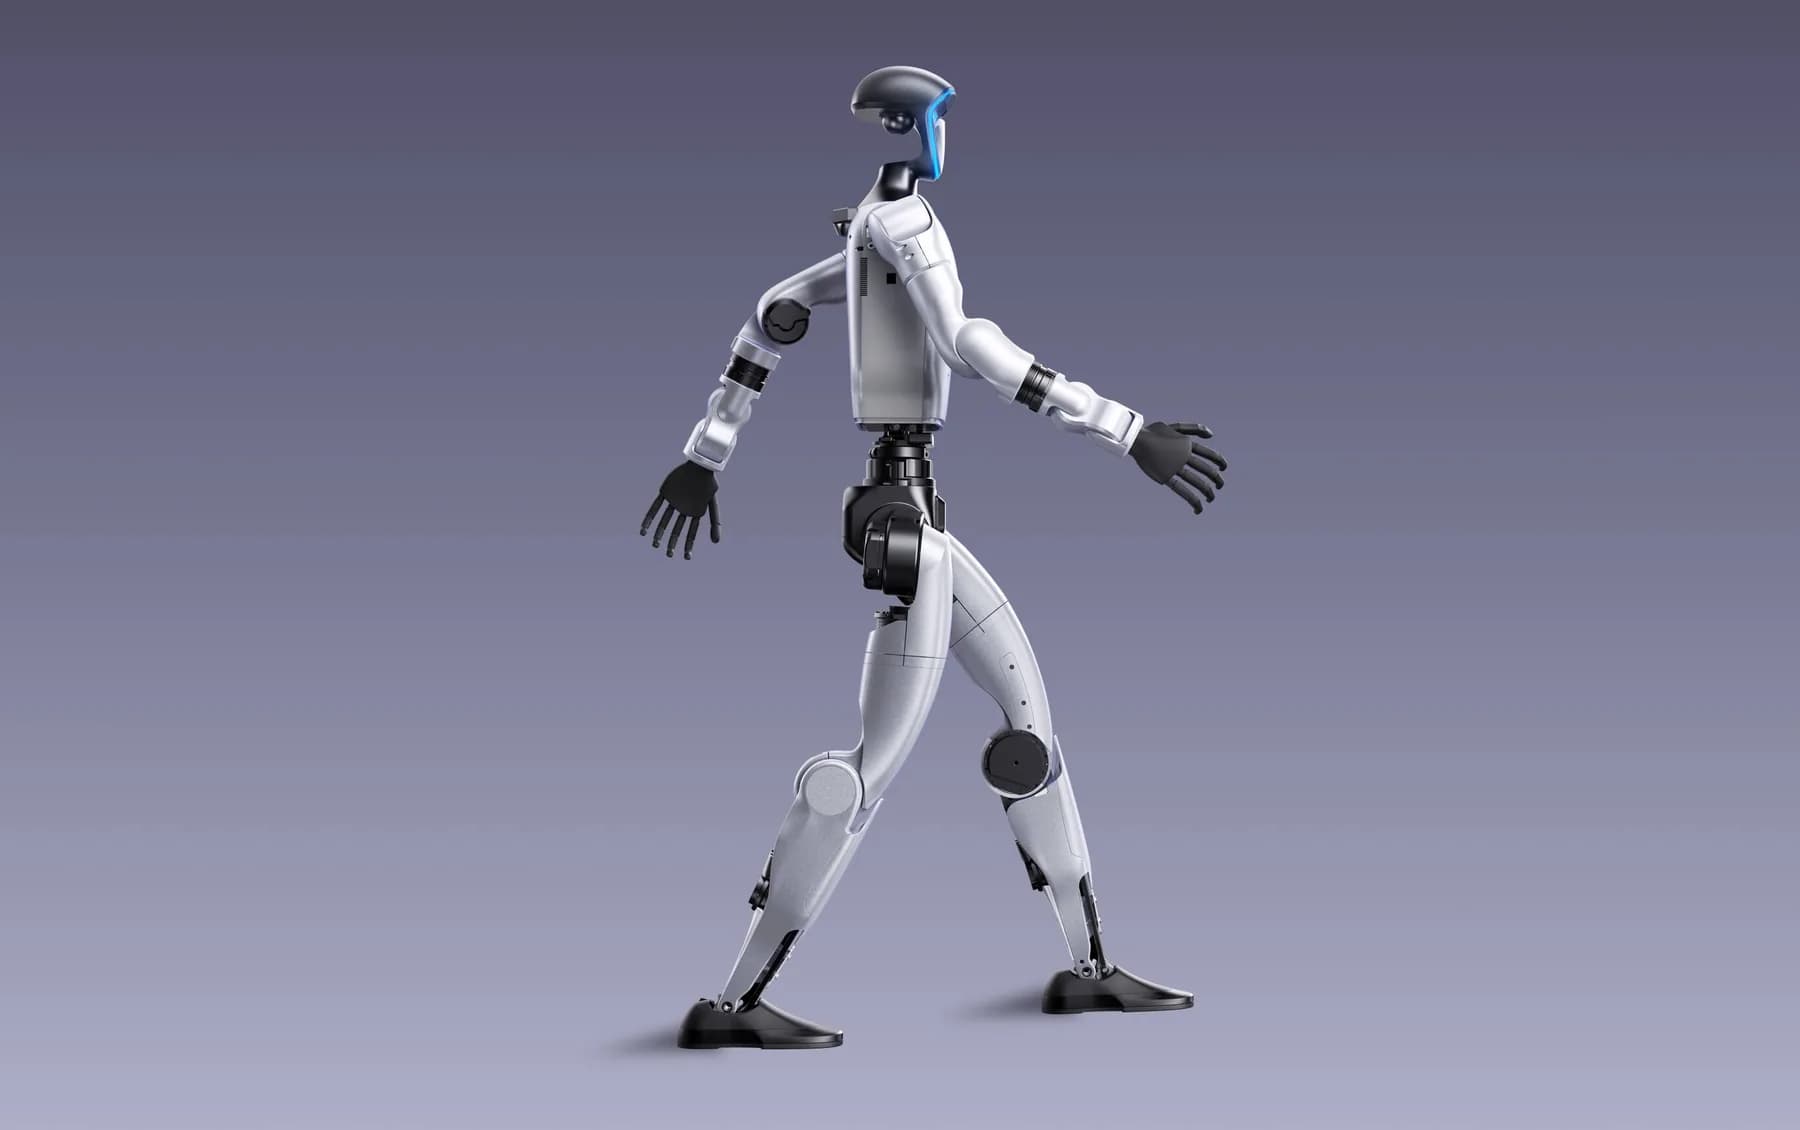
Unitree's second humanoid robot and first small-scale model, launched on May 13, 2024 and billed by the compan…
UBTech's next-generation large humanoid service robot, globally unveiled at WAIC 2021 in Shanghai on July 7, 2…